About This Work
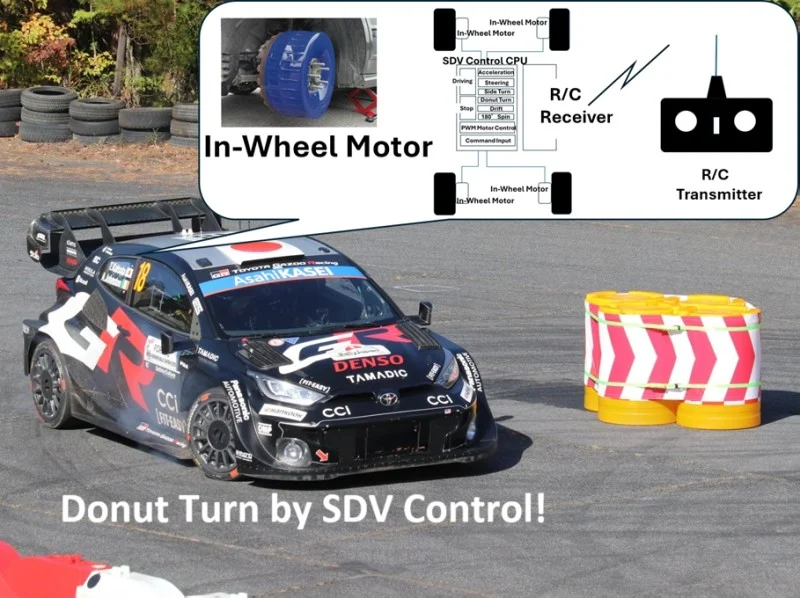
A vehicle’s behavior is determined solely by how the driver controls the tire contact patches—together roughly the size of four postcards—using the accelerator pedal, transmission, brake pedal, parking brake, and steering wheel. With in-wheel motors now available, fitting them to all four wheels and controlling each wheel’s rotational speed independently through software makes it possible to reproduce advanced driving techniques. This mechanism is expected to let anyone perform rally-style maneuvers such as donut turns, drifts, and side turns. We also hypothesize that an in-wheel motor architecture can eliminate complex drivetrain, braking, and steering mechanisms, a concept we demonstrate with a 1/10-scale model.